High-Speed, Scalable Sensor Readout for Dexterous Robotic Hands via Shift-Register Multiplexing
IEEE Robotics and Automation Letters, 2026
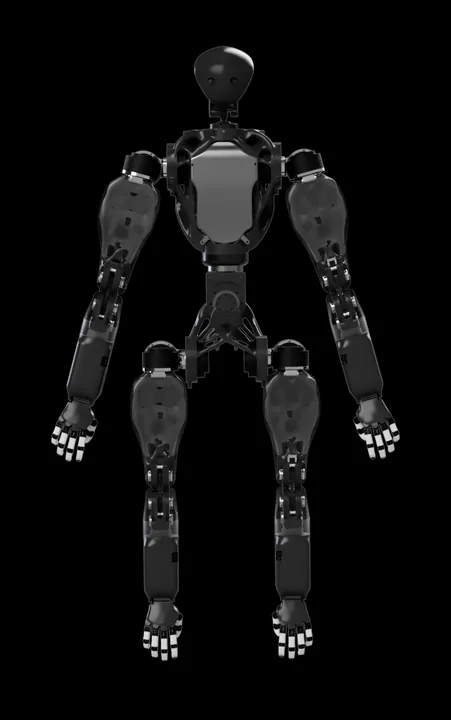
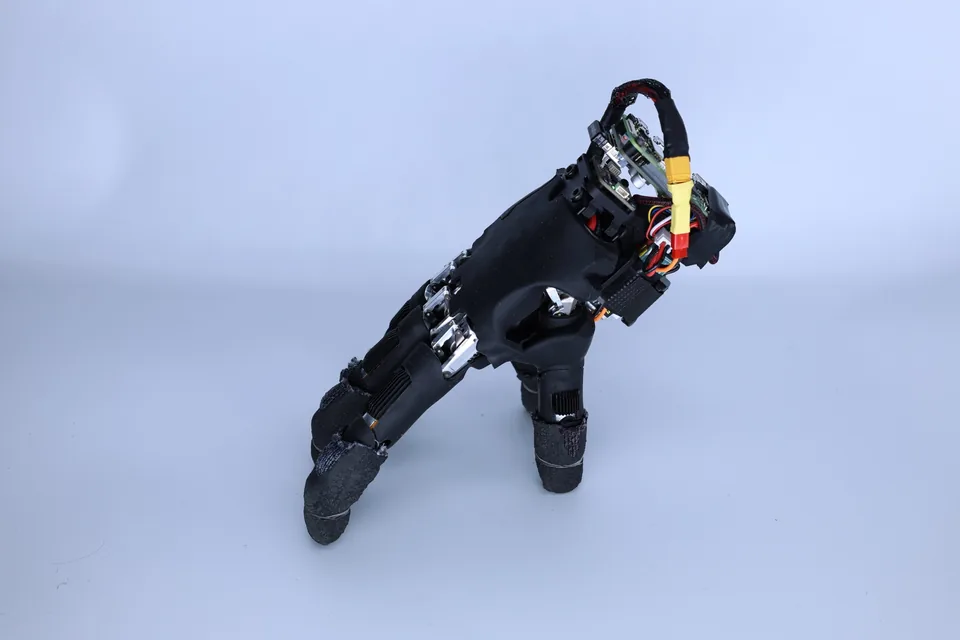
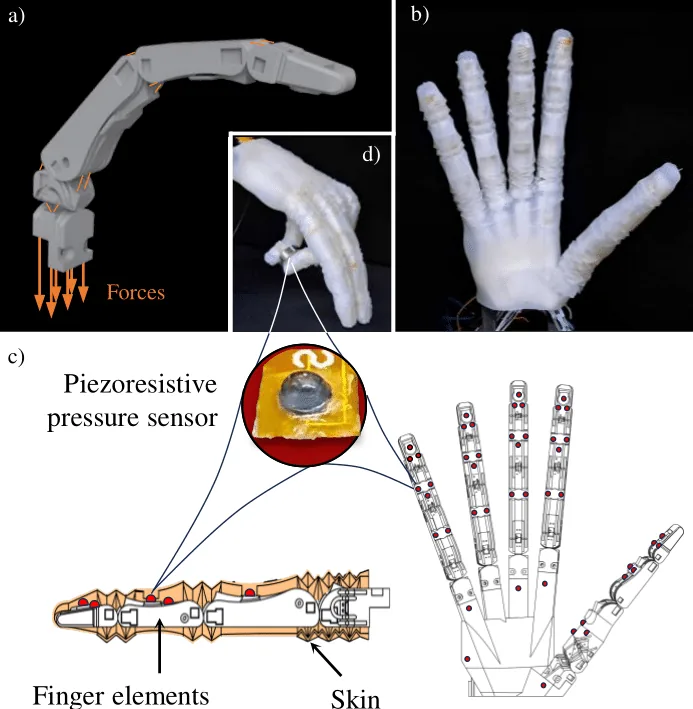
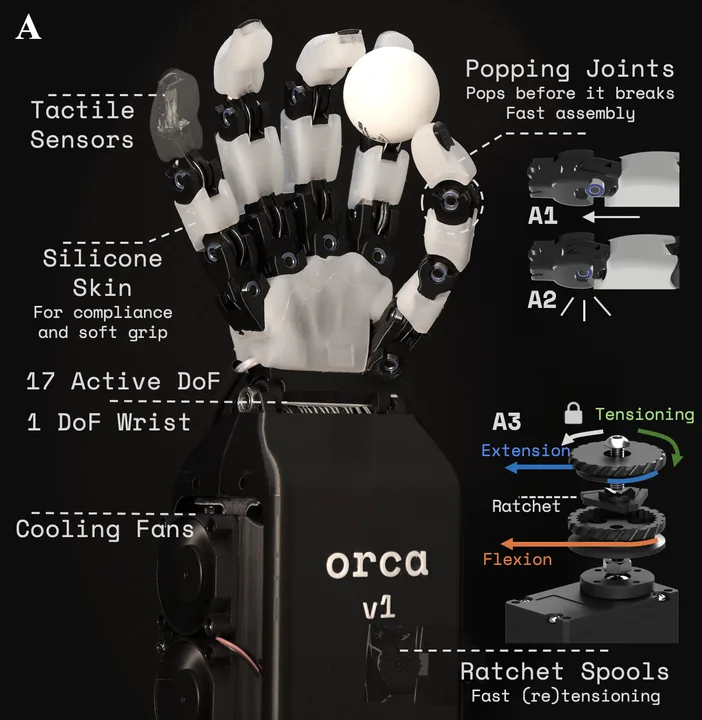
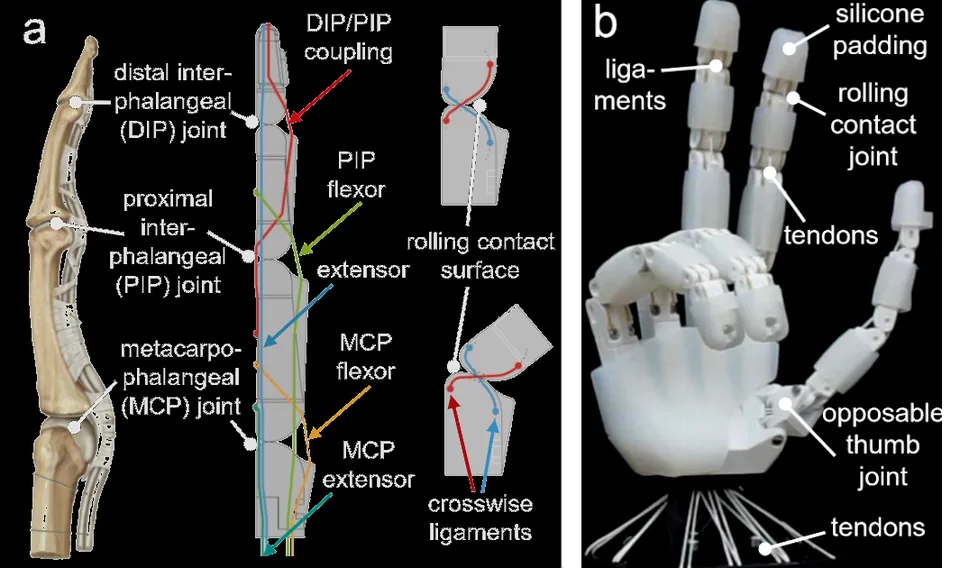
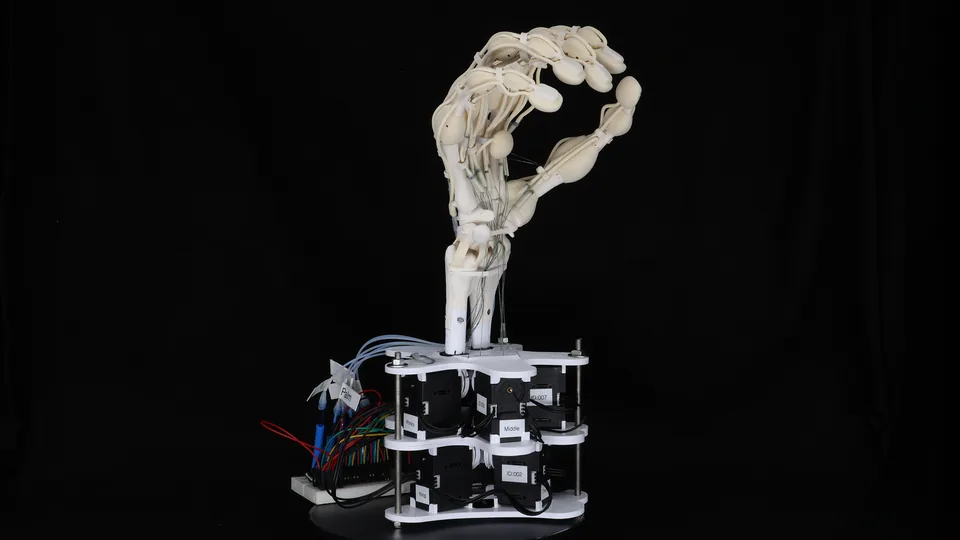
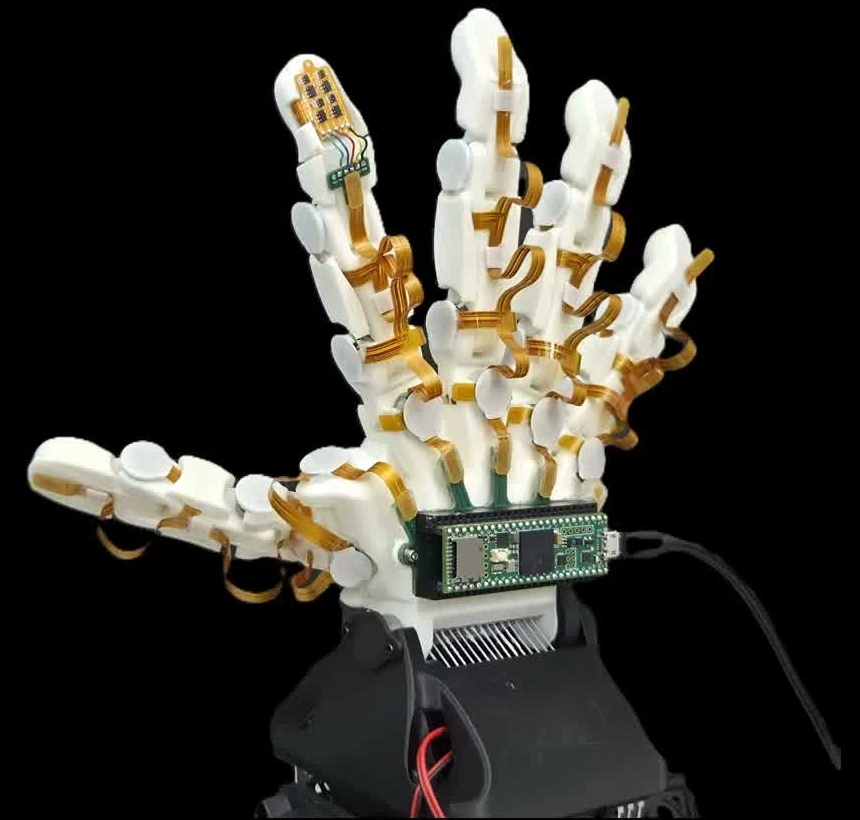
A scalable shift-register-based readout architecture integrates 20 sensing units for joint-angle and tactile sensing into a dexterous robotic hand, achieving a 1 kHz full-scan rate with three inter-module signal lines.