Modular FEM architecture
Physics is expressed through three minimal interfaces — energies, forces, and constraints — so new materials and actuators plug in without touching simulator internals.
IEEE RoboSoft 2026
* Equal contribution 1 Soft Robotics Lab, D-MAVT, ETH Zurich, Switzerland 2 ETH AI Center, ETH Zurich, Switzerland
TL;DR — SORS (Soft Over Rigid Simulator) is a modular, energy-based finite element simulator for soft robots. It handles large nonlinear deformations, near-incompressible materials, and contact via SQP-based constrained optimization, and matches real-world experiments to within a few millimeters.
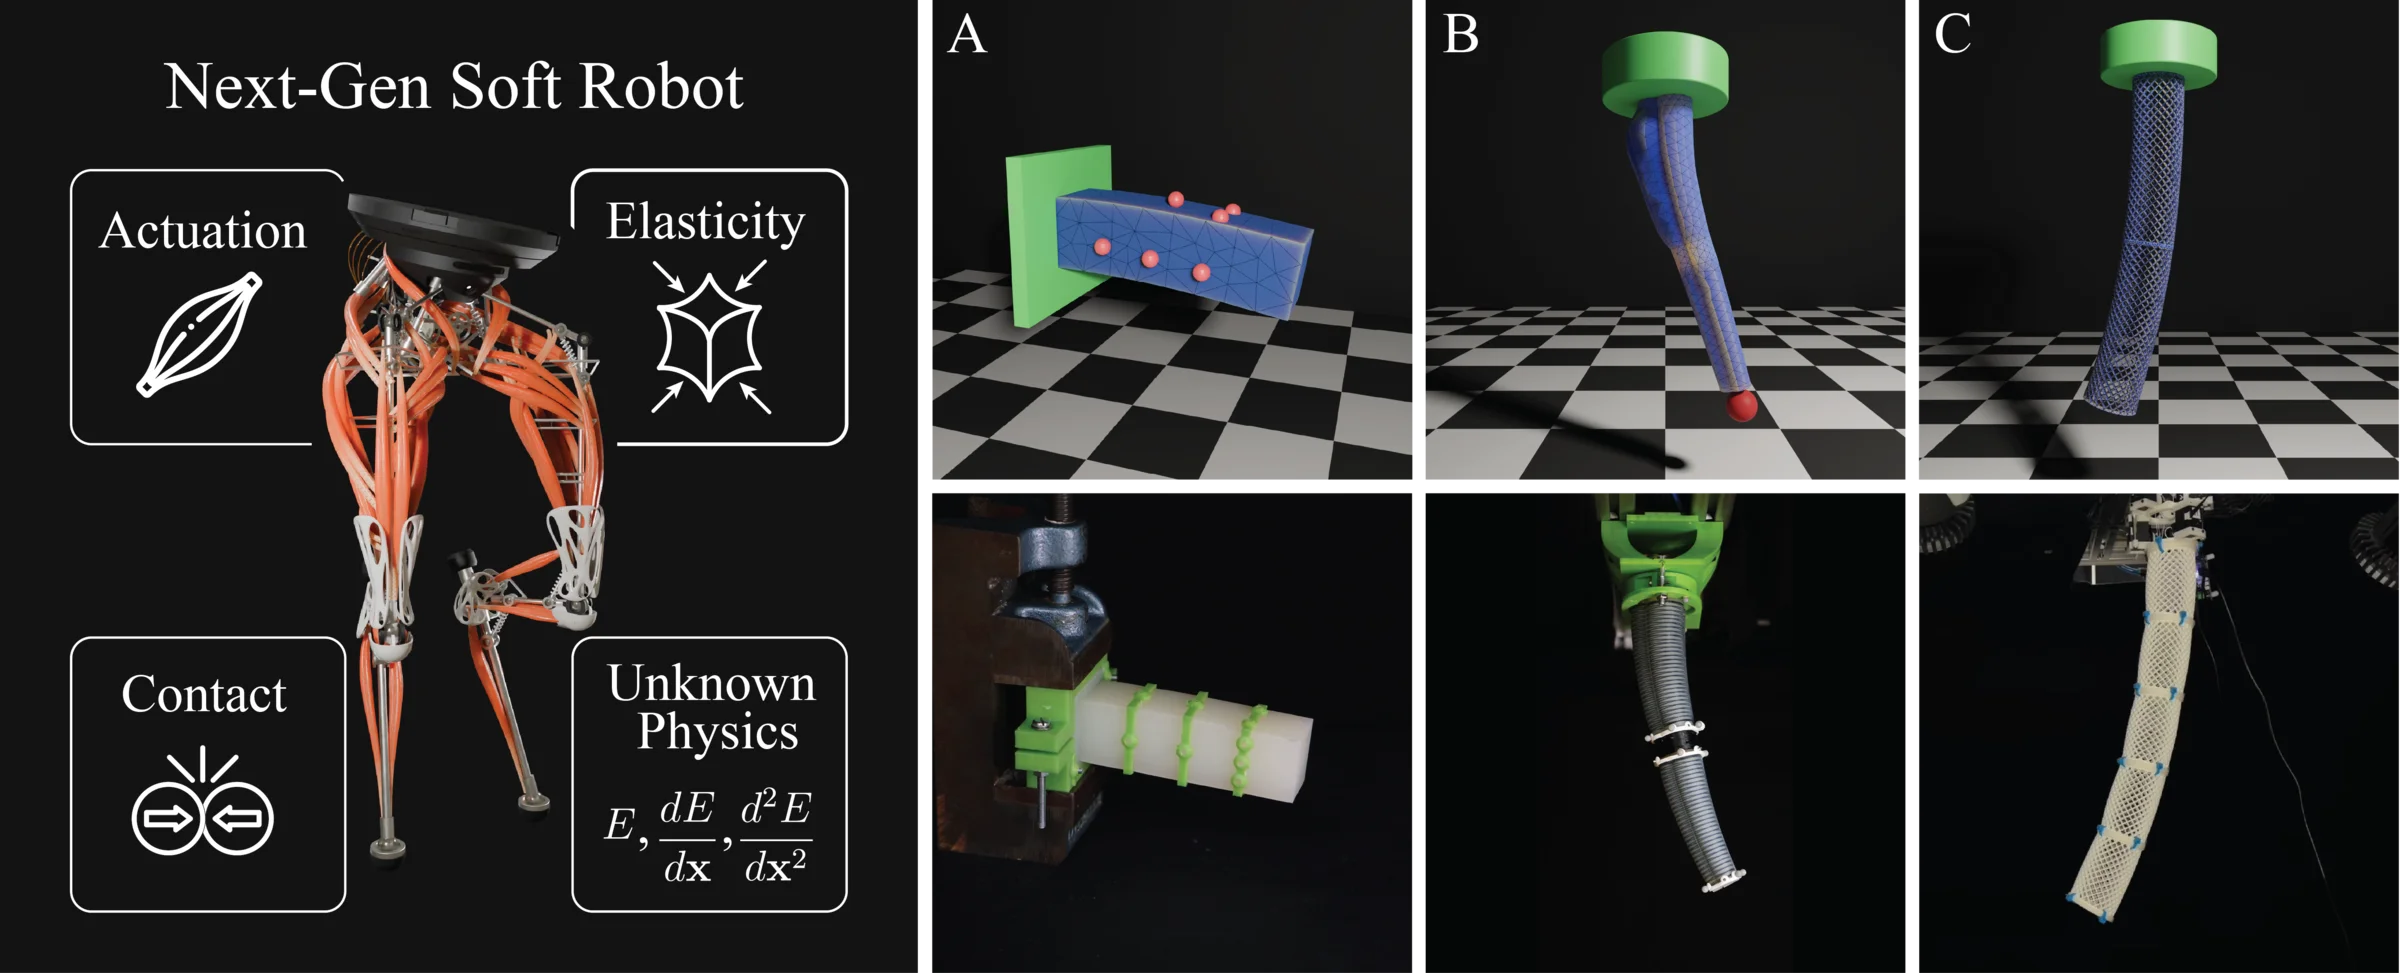
Physics is expressed through three minimal interfaces — energies, forces, and constraints — so new materials and actuators plug in without touching simulator internals.
Sequential quadratic programming (SQP) solves the constrained energy minimization, giving stable, physically consistent contact handling.
Benchmarked on cantilever deflection, PokeFlex contact, and a pressure-actuated soft arm, plus control optimization of a muscle-actuated leg.
Each experiment pairs a SORS simulation with real-world measurements.
Marker-based system identification across 17 trajectories (564 DoF) captures oscillation amplitude and phase of the real beam.

Contact-rich deformation tracked against volumetric reconstructions from the PokeFlex dataset over 10 trajectories (3813–5184 DoF).
Calibration over 6 chamber activations (3249 DoF), accurate even without explicitly modeling fiber reinforcement.

A custom optimization workflow identifies actuation timing and intensity to maximize jump height.

| Experiment | nDoF | Trajectories | Error (mm) |
|---|---|---|---|
| Cantilever | 564 | 17 | 4.98 ± 1.32 |
| PokeFlex | 3813–5184 | 10 | 6.94 ± 1.66 |
| Soft Arm | 3249 | 6 | 2.53 ± 1.16 |
Dynamics are solved via constrained energy minimization. At each iteration, SQP solves a local QP to robustly handle nonlinearities, equality constraints, and contact inequalities.
The framework decomposes physics into energies, forces, and constraints, enabling clear extension points without invasive changes to simulator internals.
New material laws, pressure or muscle actuation models, and contact formulations integrate consistently, with a C++ back end and Python front end for optimization workflows.

The deployment of complex soft robots requires simulation frameworks that not only capture multi-material interactions, but also translate accurately to real-world performance. Soft robots pose unique modeling challenges due to their large nonlinear deformations, near-incompressible materials, and contact interactions, which complicate both numerical stability and physical accuracy. We present SORS (Soft Over Rigid Simulator), a versatile, high-fidelity simulator designed to handle these complexities for soft robot applications. Our energy-based finite element framework allows modular extensions, enabling the inclusion of custom-designed material and actuation models. To ensure physically consistent contact handling, we integrate a constrained nonlinear optimization based on sequential quadratic programming, allowing for stable and accurate modeling of contact phenomena. We validate our simulator through a diverse set of real-world experiments, which include cantilever deflection, pressure-actuation of a soft robotic arm, and contact interactions from the PokeFlex dataset. In addition, we demonstrate the framework’s utility for control optimization of a soft robotic leg. These tests confirm that our simulator can capture both fundamental material behavior and complex actuation dynamics with physical fidelity. Our approach provides a tool for prototyping next-generation soft robots, filling the gap of extensibility, fidelity, and usability in the soft robotic ecosystem.
@article{mekkattu2025sors,
  author  = {Mekkattu, Manuel and Michelis, Mike Y. and Katzschmann, Robert K.},
  title   = {SORS: A Modular, High-Fidelity Simulator for Soft Robots},
  journal = {arXiv preprint arXiv:2512.15994},
  year    = {2025},
  url     = {https://arxiv.org/pdf/2512.15994}
}